Robotics
RLWRLD releases RLDX-1, a dexterity-first foundation model for robot hands
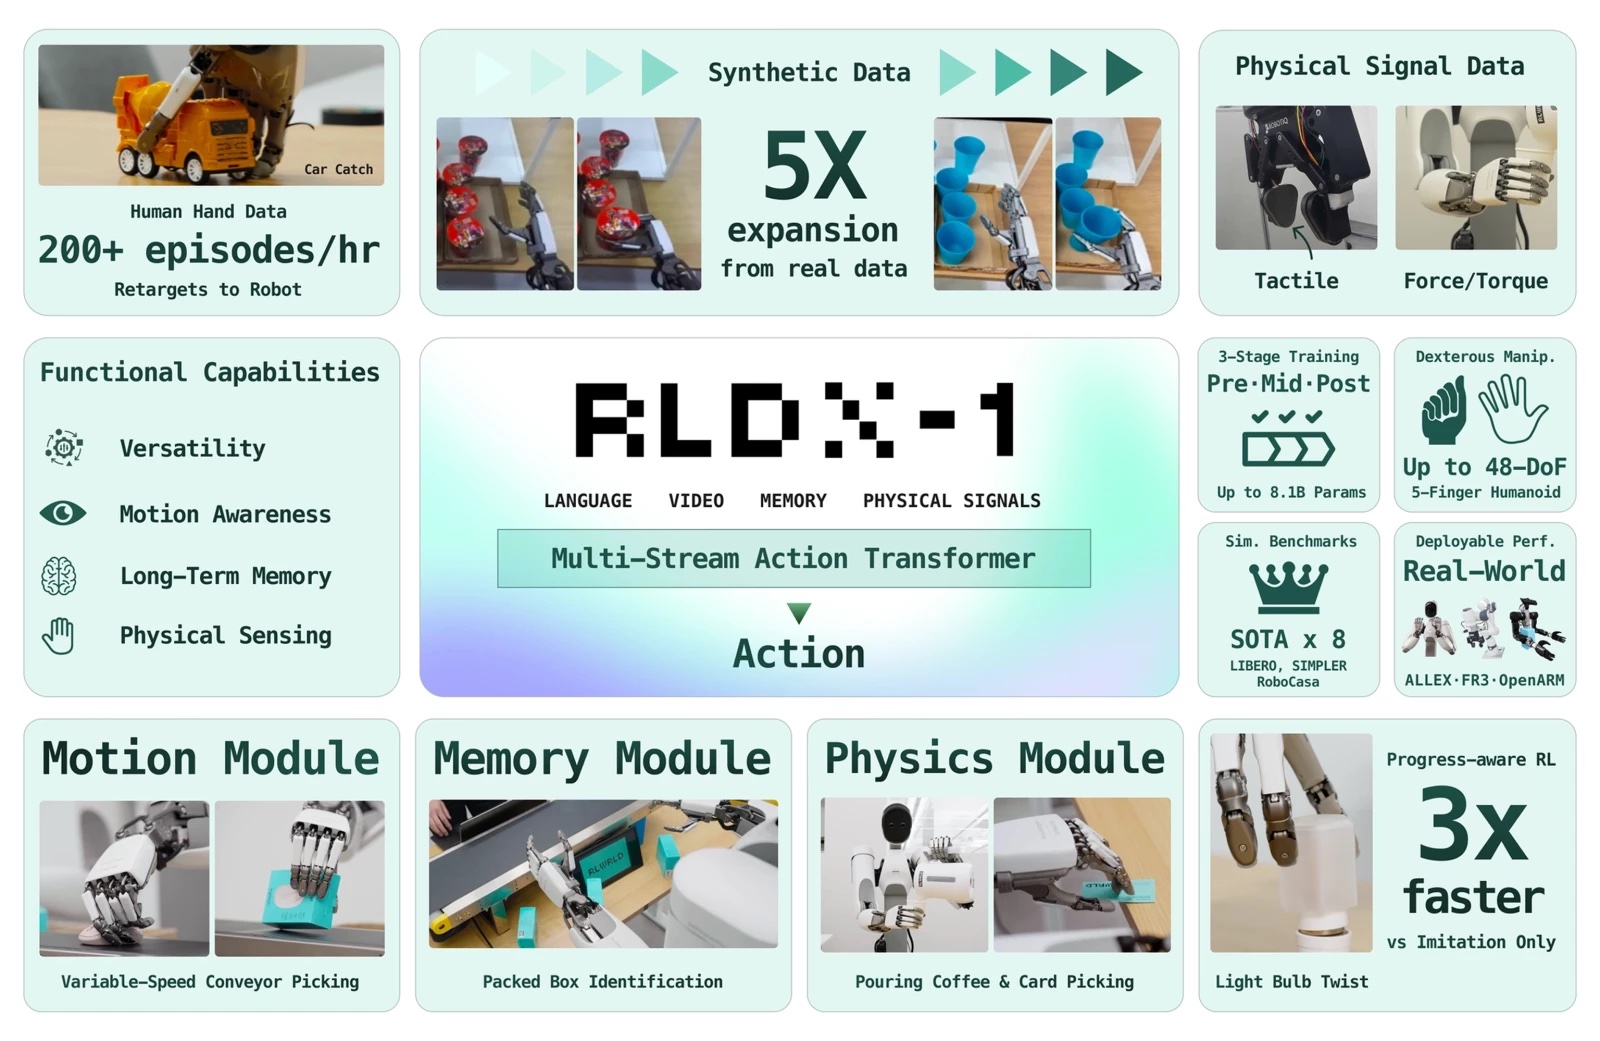
RLWRLD said with RLDX-1, it aimed to include things like context memorization or force sensing, which existing models often lack. The post RLWRLD releases RLDX-1, a dexterity-first foundation model for robot hands appeared first on The Robot Report.
TRR
The Robot Report
Source
The Robot ReportRead the full story at The Robot Report
AI Analysis
Generated insight by OnAirToday AI
RLWX-1 represents a significant leap in robot hand control by integrating context memorization and force sensing, addressing key limitations in current dexterity models. This advancement paves the way for more nuanced and adaptive robotic manipulation in complex real-world tasks.
Powered by AI • Not a substitute for human analysisMore Insights →
Share
Filed under:Robotics
Comments
Keep comments relevant and respectful. No links, advertising, self-promotion, or spam.